
Servo motor & drive maintenance
How to test a servo motor, its encoder, brake and drive with real instruments, trace an alarm to its cause, then repair, tune and put the axis back into production. You start with safety and discharging the drive capacitors, then windings, insulation and Back-EMF, then every encoder type, how to test and replace it and set the commutation offset, then the brake, bearings and cables, then the drive itself, its alarms and its tuning. Built on IEC 60034, IEC 61800, IEEE 43 and the manufacturers' manuals, with the repair of a CNC machine axis, from the alarm to the first good part, as the project.
The first lesson is free; both simulators open with the course
The lessons are in Arabic for now; the English version is on the way. Symbols, units and standards are the same as in the real documents.
13 lessons in order, each followed by a simulator exercise
Every test is worked through step by step with real numbers. Every lesson has a quiz; the last one has the project and the final exam.
- Safety in servo system maintenanceFree
- QuizLesson questions
- Inside the servo motor and its nameplate
- QuizLesson questions
- Testing the servo motor windings
- QuizLesson questions
- Every encoder type
- QuizLesson questions
- Encoder testing and faults
- QuizLesson questions
- Encoder replacement and commutation offset
- QuizLesson questions
- The servo motor brake
- QuizLesson questions
- Bearings, seals and magnets
- QuizLesson questions
- Cables, earthing and noise
- QuizLesson questions
- Drive maintenance: the circuit and its parts
- QuizLesson questions
- Alarms and how to diagnose them
- QuizLesson questions
- Tuning after the repair
- QuizLesson questions
- Project: repairing a CNC machine axis + the final exam
- QuizLesson questions
- ExamFinal exam
The course in numbers
What you'll learn
- Work safely on servo systems: discharge the DC bus capacitors, support vertical axes and suspended loads, and isolate and lock out
- Read a servo motor nameplate, work out the torque constant and electrical frequency, and identify the power, brake and encoder pins
- Measure winding resistance and balance, test insulation without damaging the encoder, and measure the Back-EMF to work out Ke
- Identify every encoder type: incremental TTL and HTL with Hall, Sin/Cos, resolver, single- and multi-turn absolute, EnDat, BiSS, SSI, HIPERFACE and DSL
- Check each encoder's signals on the scope, and find supply, battery, communication, count and cable faults
- Replace an encoder and set the commutation offset by DC injection and by the Back-EMF method
- Test the brake's release voltage and time, holding torque and air gap, and diagnose bearings, seals and demagnetisation
- Track down cable, shield, 360° earthing and electromagnetic noise faults
- Open a drive safely, diode-test the rectifier and IGBTs, check the capacitors, braking resistor and fan, and diagnose alarms by measurement
- Tune the axis after a repair: inertia ratio, loop gains and the notch filter, then repair a whole CNC axis and return it to production
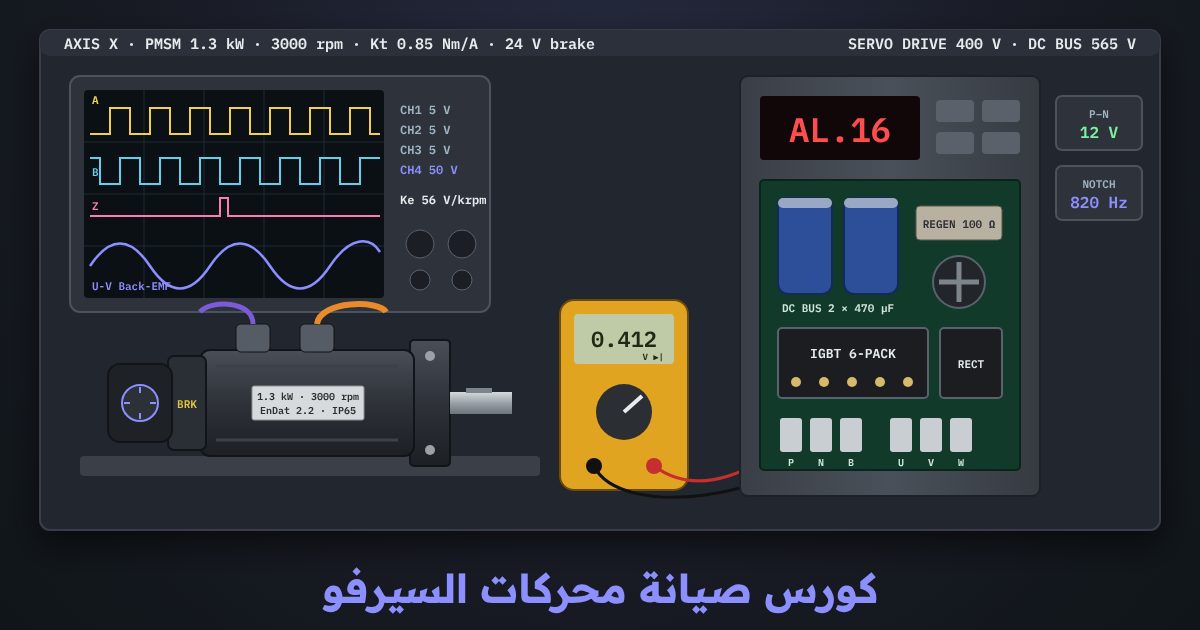
Servo motor bench and servo drive station: 12 exercises
A real servo motor on the bench, measured with a multimeter, a megger and an oscilloscope, and a servo drive to open, test, diagnose and tune. Each exercise belongs to a lesson and counts toward your progress.
- Nameplate and connectorsRead the nameplate of the X-axis motor, work out the torque constant Kt, the electrical frequency and the peak torque, then identify the power, brake and encoder pins from the manual
- Windings, insulation and Back-EMFMeasure the three winding resistances and their unbalance, test the insulation with the encoder and brake disconnected, then turn the shaft, read the Back-EMF on the scope and work out Ke
- Encoder typesIdentify every encoder type from its connector, signal and label: TTL and HTL with Hall, Sin/Cos, resolver, EnDat, BiSS, SSI, HIPERFACE, DSL and battery-backed absolute, and wire each one to the right drive input
- Encoder scope testingProbe the test points and read A/B/Z, the differential pairs, the Sin/Cos circle, the resolver envelopes, the serial frames, the supply and the battery, then name the fault
- Encoder replacement and commutation offsetReplace the axis encoder in the right order, set the commutation offset by DC injection, then refine it with the Back-EMF method
- Holding brakeSupport the vertical axis, measure the brake coil and release voltage, read the release and engage times on the scope, and test the holding torque
- Bearings and magnetsDiagnose bearing noise and vibration, oil past the shaft seal, and demagnetisation from the Back-EMF and the current, then choose the cause and the fix
- Cables and noiseTrack down a broken shield, a missing 360° earth clamp, power and encoder cables run together, and a damaged encoder pair, and pick the fix for each
- Drive componentsIsolate and lock out, wait for the DC bus to discharge, diode-test the rectifier and the IGBTs, check the capacitors and ESR, the braking resistor and the fan, and find the failed part
- Alarm diagnosisClear real alarms on the drive display: measure with the right instrument in the right safe state, then choose the root cause and the repair
- Tuning after the repairEstimate the inertia ratio, raise the speed-loop gain, remove the resonance with a notch filter, and set the position gain until the following error is within limits
- CNC axis projectA CNC machine axis is down: read the alarm, make the machine safe, diagnose by measurement, repair in order, then restart until a good part comes out
Who this course is for
- Maintenance engineers and technicians in plants with CNC machines, filling lines, robots and servo axes
- Anyone facing an encoder alarm, an overcurrent or a following error who wants to find the cause by measuring, not guessing
- Motor and drive repair-shop technicians who want to understand the tests before and after a repair
- After the servo course and the motor & transformer maintenance course; every test is worked through with numbers
Before you ask
Do I need a real servo or test instruments?
How is it different from the servo course?
Do I need an account?
Is there a certificate?
Ready to repair your first axis?
The first lesson is free; the whole course with both simulators opens when you buy it. Start now and continue at your own pace; your progress is saved.